G00 Rapid Traverse in CNC Programming: Complete Guide & Examples
One of the codes that must be learned before working on a CNC machine is G00. This command moves the tool from one point to another very quickly. In this, the tool does not cut, but only changes its positioning.
In CNC programming, this command is used to move the tool from one point to another at rapid speed without cutting. If you are learning basic CNC programming, understanding the difference between G00 and G01 should be your first priority.
G00 is also called Rapid Positioning or Rapid Traverse. This command works until another command (such as G01, G02 or G03) comes.
Related: G00 vs G01: Simple CNC example
Let’s try to understand this code with an example. When
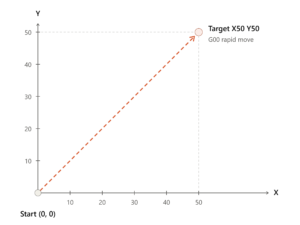
G00 X50. Y50. is written in the program, the machine works in the following way:
That’s a G-code rapid positioning command: G00 moves the tool at maximum speed (non-cutting) to the position X50, Y50 (typically in mm, or inches depending on your active unit mode).
Note: Since the tool moves at a very high speed, G00 is never used during cutting. G01 (Linear Feed) is always used for cutting.
Basic Syntax of G00
G00 X__ Y__ Z__X, Y, Z: The coordinates of the axes where the tool should move. This command does not require a feed rate (F), as the speed is the machine’s own rapid traverse.
Example:
G00 X50.0 Y25.0
G00 Z5.0
Example: Milling program
G21 G90 G17 G54
M03 S2000
G00 X0 Y0
G00 Z10.0
G00 X30.0 Y20.0
G00 Z2.0
G01 Z-3.0 F100
G01 X80.0 F200
G00 Z10.0
M05
M30
Example: Lathe (Turning) program
G00 X50.0 Z5.0
G00 X30.0
G01 Z-40.0 F0.2
G00 X52.0
G00 Z5.0
In G00 (rapid positioning), the tool moves at the maximum rapid speed set in the machine parameters, which can be different for each axis.
This command is only for changing positioning, not for cutting, because it does not have feed control or cutting conditions.
G00 is a modal command, that is, it remains active until G01, G02 or G03 is issued, and the F value has no effect on it, however, the previously given F value is preserved and is later applied to G01.
The path in this is not always a straight line, because in many controllers each axis moves at its own speed (non-linear interpolation) and the axis that reaches it first stops, which can cause the path to be crooked, so caution is required.